Detail Future | Build High Level Human-Robot Collaboration Data Foundation
As humanoid robots gradually enter real-world scenarios, relying solely on fixed-action demonstrations can no longer meet the demands of complex human-robot collaboration.
In real environments, robots must not only complete tasks but also respond to human interventions, task adjustments, and environmental changes, and understand human actions, language, and state changes during interaction. To achieve this, in addition to model capabilities, high-quality human-robot interaction data is equally critical.
Along this direction, Detail Future's core R&D team, together with Dr. Li Xingxing's research group at Beijing Institute of Technology, has officially launched a human-robot bidirectional interaction multimodal data R&D project, while simultaneously building a human-robot interaction data collection test platform to comprehensively explore pathways for collecting human-robot interaction data and productizing it for embodied intelligence. Backed by its domestic R&D team and Singapore-based overseas business operations entity, these high-quality data products will also serve the global embodied AI market in the future.
Industry Landscape:Data Coverage for Dynamic Human-Robot Collaboration Remains Limited
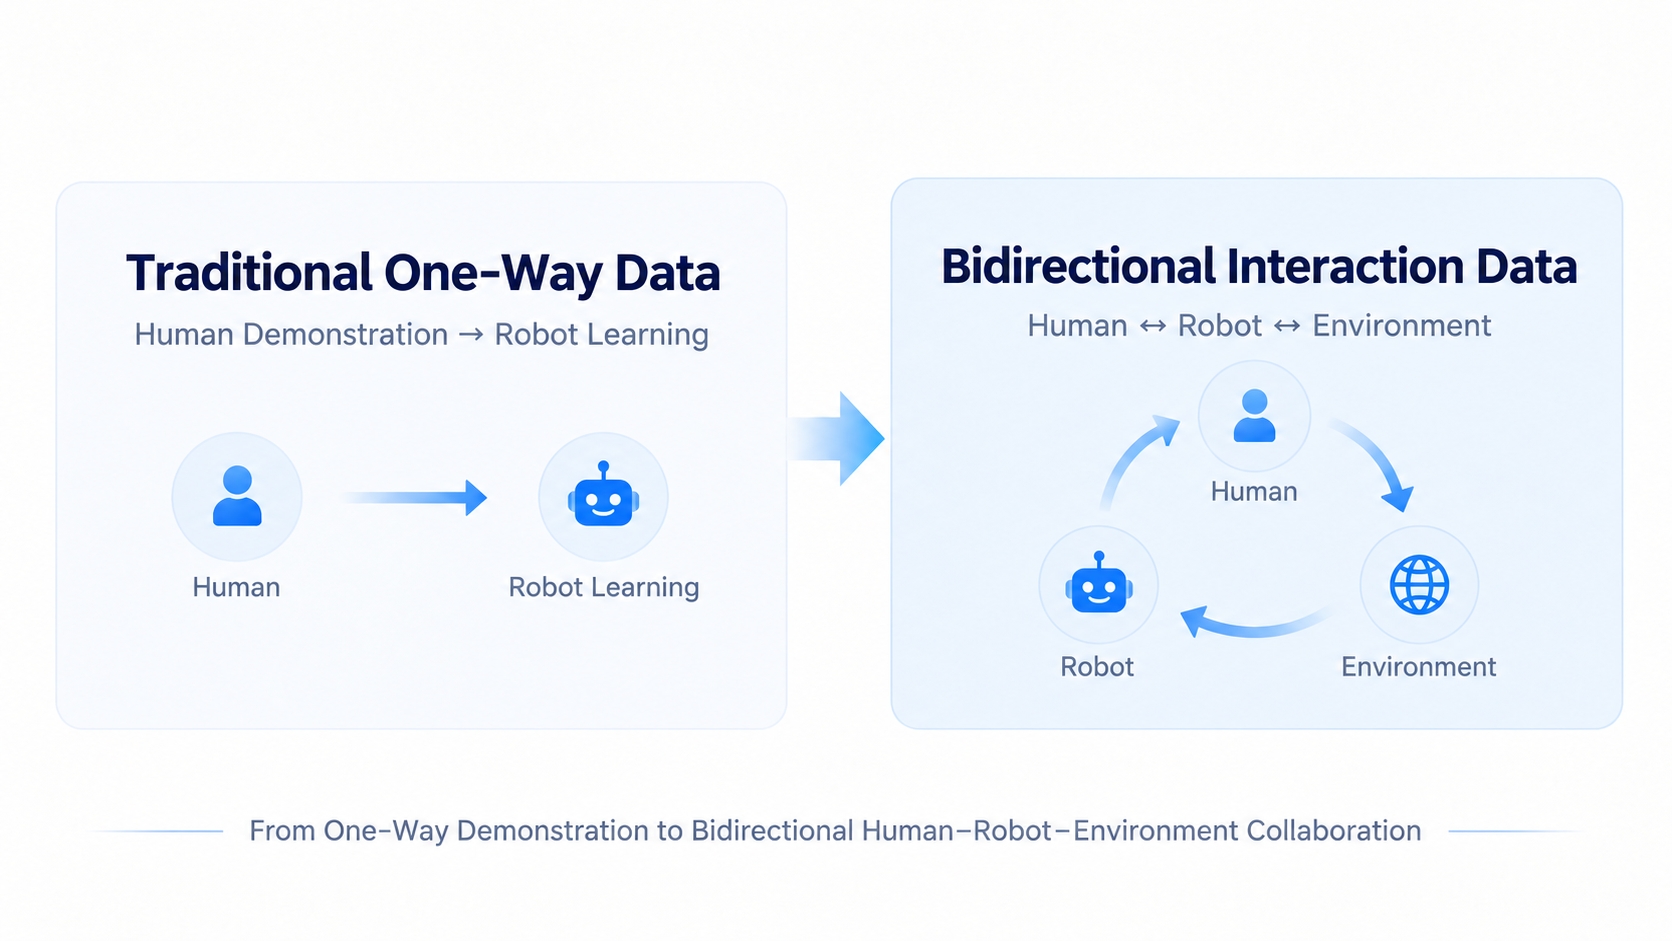
Currently, data collection in the industry is largely concentrated on robots operating independently or on one-way demonstrations from humans to robots. Such data is suitable for training well-defined tasks such as grasping, handling, and organizing, but human-robot collaboration in real scenarios is often far less fixed.
For example, when a robot deviates during task execution, a person may temporarily halt it, adjust the action, or even change the original task objective. Human judgment is not only reflected in actions and language — subtle changes such as reaction speed, pauses, and avoidance are equally critical signals that affect subsequent interactions.
Therefore, for more complex human-robot collaboration tasks, recording only "what the robot did" is not enough; it is also necessary to record when humans intervene, how the robot responds, and how both parties continue to complete the task together. This is precisely the part that is relatively lacking in existing public data.
Industry-Academia Collaboration:Building a Human-Robot Co-Collection Test Platform
Detail Future joins hands with the research team led by Dr. Li Xingxing at Beijing Institute of Technology, combining academic sensing capabilities with mature humanoid robot platforms to build human-robot collaboration test scenarios.
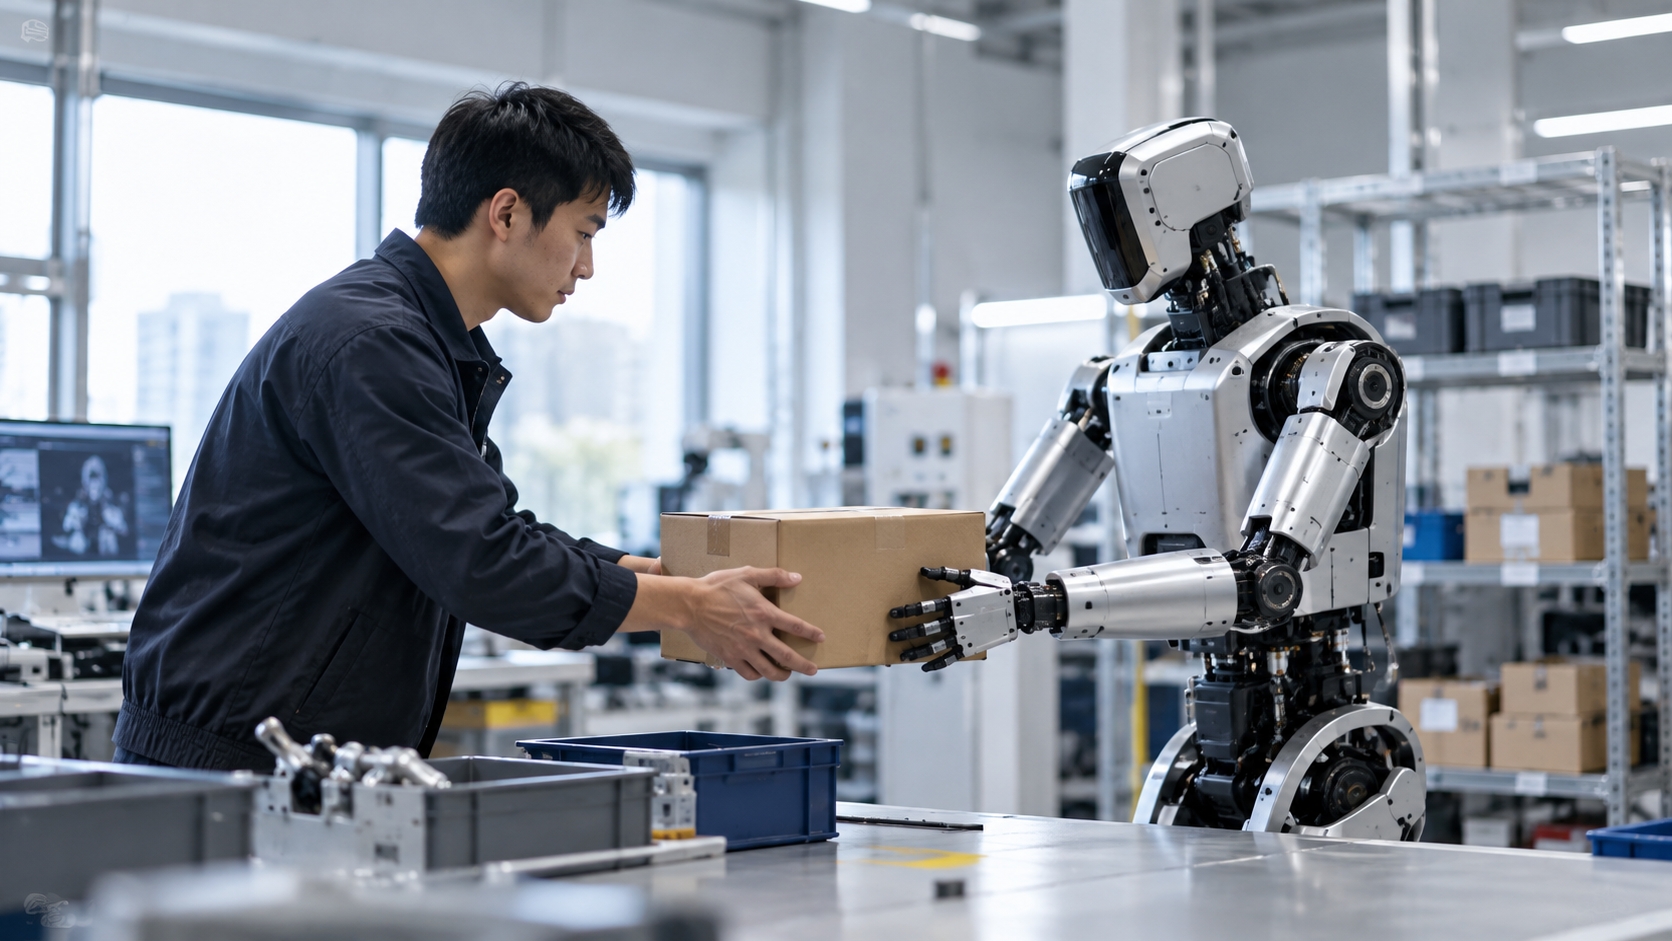
The project is also open to humanoid robot manufacturers for joint co-building, welcoming manufacturers to participate in scenario testing, data collection, and solution iteration. The standardized commercial datasets subsequently developed will also be prioritized for co-building enterprises.
In terms of collection methods, the project does not rely on fixed scripts, but rather records human-robot interaction processes closer to real conditions through environmental changes and task perturbations. The data will cover human behavior, speech, physiological sensing signals, robot proprioceptive sensing, and multi-view environmental perception information, all aligned through multimodal temporal synchronization. After collection, the data undergoes multi-layer screening, cleaning, event annotation, and quality inspection, ultimately forming standardized commercial data assets usable for model training and evaluation.
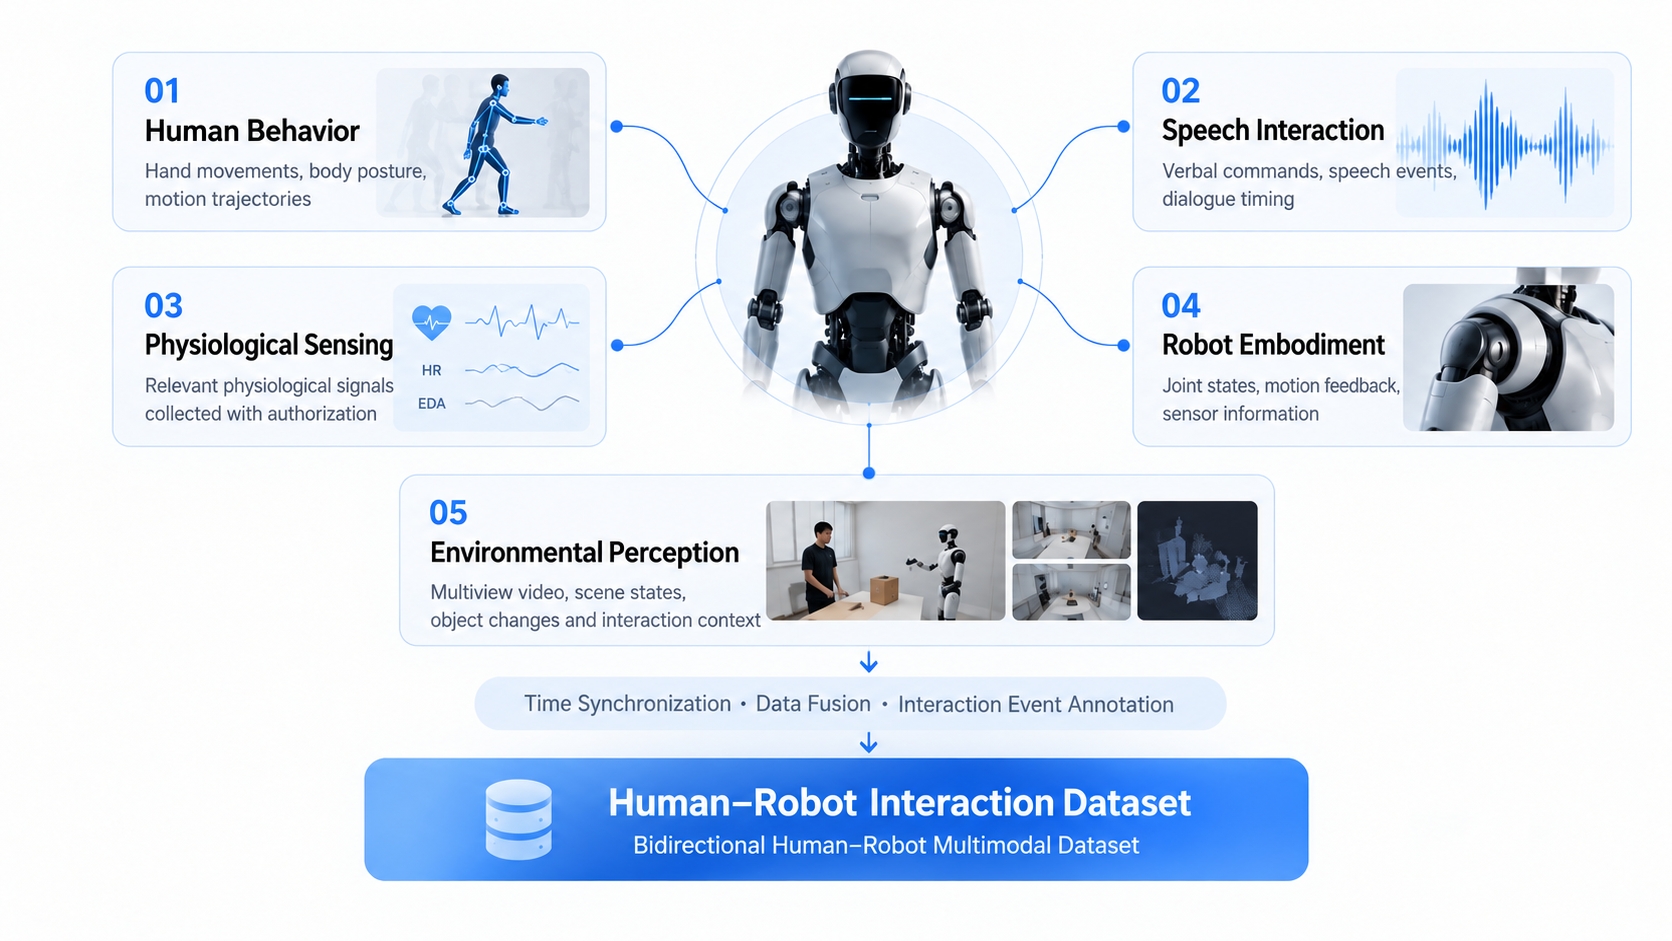
The core goal of the project is to completely record the full process of bidirectional human-robot interaction: not only tracking what the robot did, but also understanding why humans intervened, how their states changed, and how these changes influenced the robot's next actions.
Market Differentiation:From Single-Agent Operation to Human-Robot Collaboration
Currently, embodied data on the market remains dominated by single-agent operation, teleoperation, and fixed-task data. The focus of Detail Future's project, however, is on dynamic human-robot collaboration scenarios, mainly reflected in three aspects:
Scenario: Focusing on real-time intervention, task adjustment, human-robot collaboration, and open-environment interaction;
Data: Recording not only actions, but also combining speech, state signals, and robot proprioceptive information;
Product: Further organizing research collection outcomes into datasets that can be directly used for training, evaluation, and commercial projects.
The project will fully leverage academic research capabilities and mature robot platforms, focusing on scenario design, multimodal synchronization, data processing, and product standardization. The data generated will, on the one hand, support research teams in model research, and on the other hand, provide commercial and customized services to humanoid robot manufacturers, embodied algorithm teams, and research institutions.
Roadmap
The project will advance in phases:
Prototype pipeline validation → Scenario expansion and pilot testing → Release of standardized datasets
Meanwhile, Detail Future can also provide customized human-robot interaction data services based on different robot platforms and task requirements. For co-building manufacturers, the project team will conduct joint testing with them, continuously optimizing collection schemes and data standards on real robot platforms.
About Detail Future
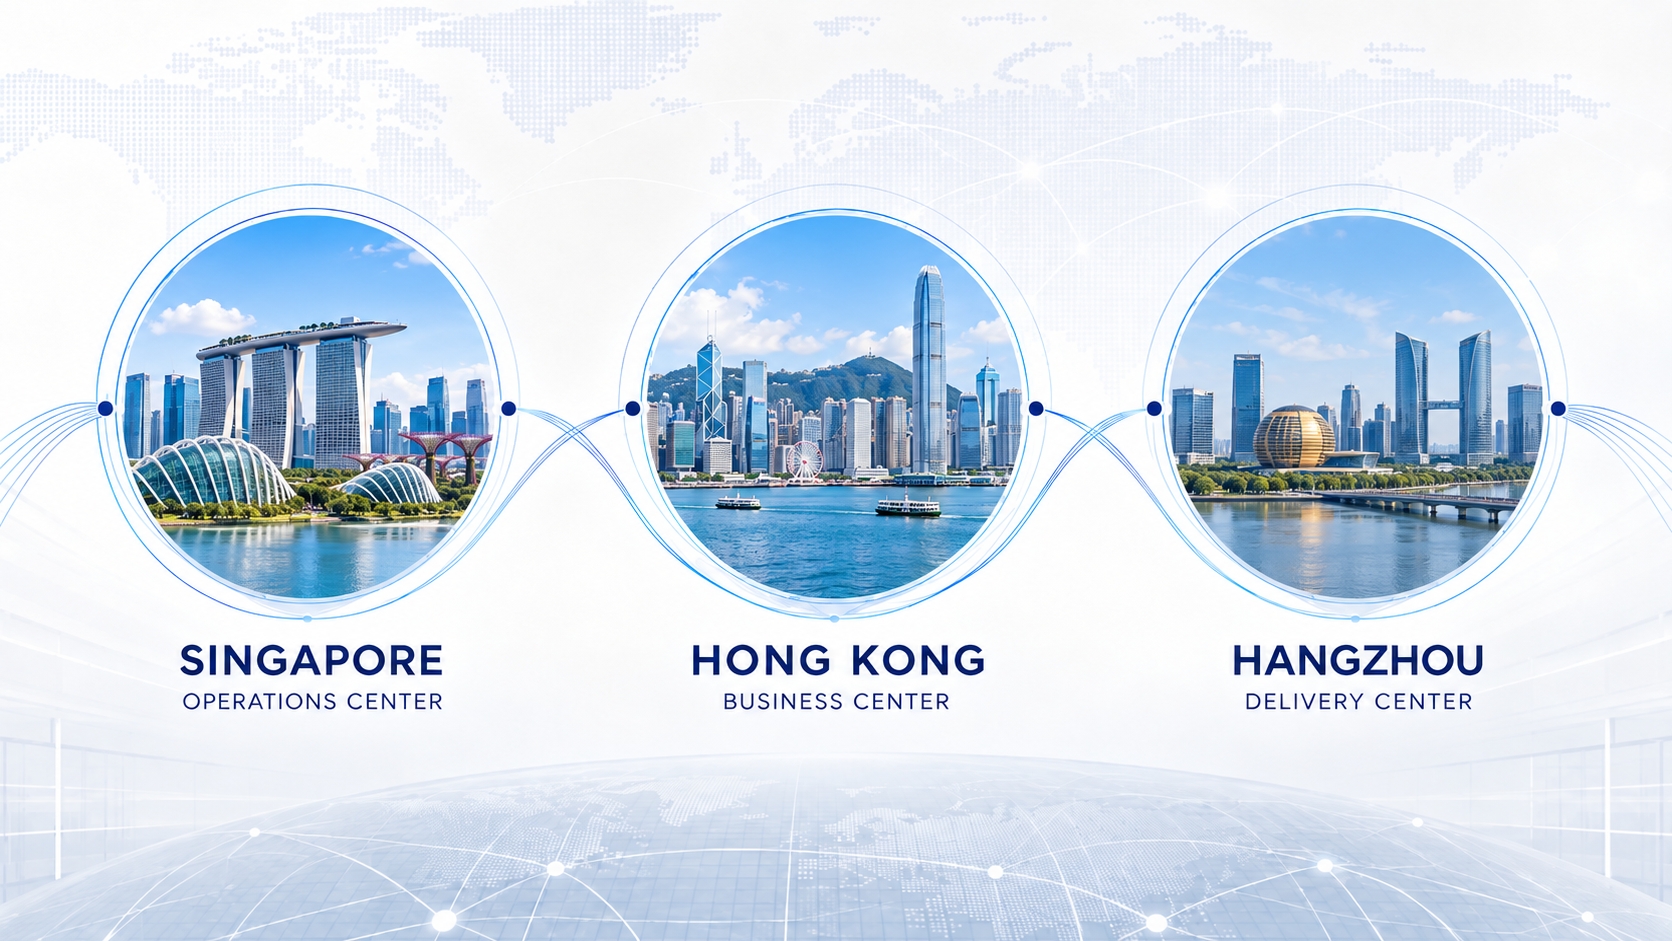
Detail Future's headquarters are located in Singapore, with Hangzhou established as its domestic delivery entity in China, focusing on the construction of a Physical AI and embodied intelligence data foundation.
The company brings together a cross-disciplinary technical team and maintains collaboration with academic research teams, conducting R&D around real-world data, multimodal perception, human-robot interaction, and world models, providing data collection, processing, evaluation, and delivery services to robot manufacturers, algorithm teams, and research institutions.
We welcome humanoid robot manufacturers, embodied algorithm teams, and research partners to connect with us.